Camera
最后更新
Camera 是一个单一的统一源节点,它取代了单独的 ColorCamera 和 MonoCamera 节点。它生成 ImgFrame 消息,可用于图像处理和神经网络推理。主要功能
- 自动选择传感器分辨率和 FPS,当您未指定时——无需手动记录。
requestOutput()
Py
1cam.requestOutput(size=(640, 480), type=dai.ImgFrame.Type.NV12,
2                resize_mode=dai.ImgResizeMode.CROP,
3                enableUndistortion=True,
4 alphaScaling=0.0)- 通过
enableUndistortion(默认 =False)选择性地为每个输出启用去畸变。它不会自动应用于任何流。 - 当启用去畸变时,
alphaScaling可选择控制裁剪和保留完整视野之间的平衡。 - 去畸变不会改变存储的相机内参;有效 FOV 仍然取决于请求的输出大小、调整大小模式和
alphaScaling值。 - 通过
CameraControl进行运行时曝光控制,包括当您希望自动曝光保持在选定 ISO 上限以下时使用setAutoExposureMaxISO()。 requestFullResolutionOutput()带有安全防护(除非您传递useHighestResolution=True,否则保持 ≤ 5 K×4 K)。setMockIsp()用于合成或录制输入(连接ReplayVideo节点以馈送预捕获帧)。
ColorCamera 或 MonoCamera 升级?只需搜索并替换节点创建并删除任何手动 setIspScale() 逻辑。放置节点
Python
Python
1with dai.Pipeline() as pipeline:
2    cam = pipeline.create(dai.node.Camera)
3 cam.build(dai.CameraBoardSocket.CAM_A) # 可选 — 否则自动检测输入和输出
调整大小模式
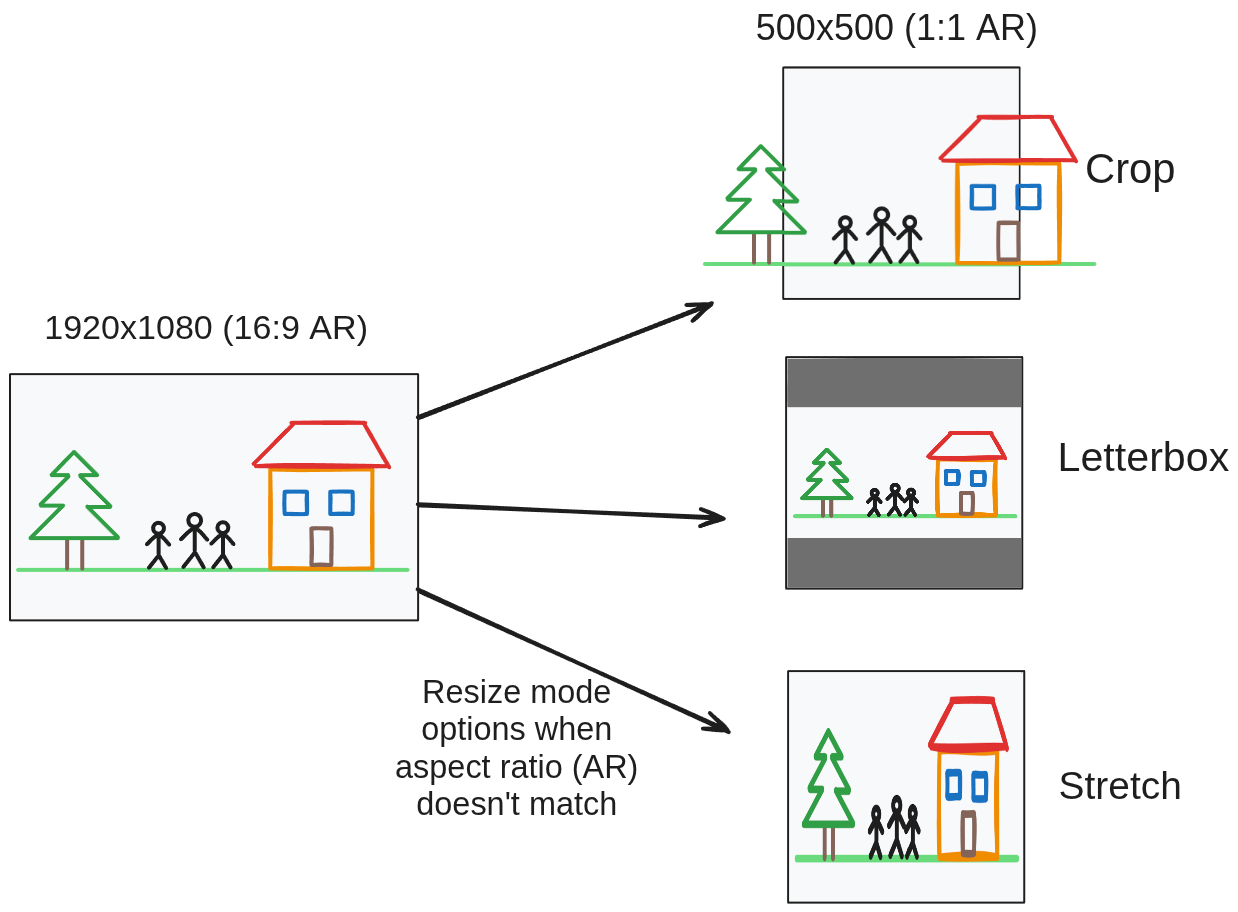
- 裁剪:神经网络精度不下降。缺点:帧被裁剪,因此不是完整 FOV。
- 信箱:保留完整 FOV。缺点:较小的“帧”可能意味着较少的特征,从而降低神经网络精度。
- 拉伸:保留完整 FOV。缺点:由于帧被拉伸,神经网络精度可能会下降。
Python
1cam.requestOutput(size=(640, 480), type=dai.ImgFrame.Type.NV12,
2                resize_mode=dai.ImgResizeMode.CROP)
3cam.requestOutput(size=(640, 480), type=dai.ImgFrame.Type.NV12,
4                resize_mode=dai.ImgResizeMode.RESIZE)
5cam.requestOutput(size=(640, 480), type=dai.ImgFrame.Type.NV12,
6                resize_mode=dai.ImgResizeMode.LETTERBOX)
使用示例
Python
Python
1pipeline = dai.Pipeline()
2
3cam = pipeline.create(dai.node.Camera)
4cam.build(boardSocket=dai.CameraBoardSocket.CAM_A)
5
6# 1) 用于视频编码器的低延迟预览
7nn_in = cam.requestOutput(size=(300,300), type=dai.ImgFrame.Type.NV12, fps=30)
8
9# 2) 用于录制的 HD 流
10hd_out = cam.requestOutput(size=(1280,720), type=dai.ImgFrame.Type.BGR888p, fps=30)
11
12# 3) 每秒全分辨率静止图像
13full = cam.requestFullResolutionOutput(type=dai.ImgFrame.Type.BGR888p, fps=1)
14
15# 链接到下游节点...自动曝光 ISO 上限
Python
Python
1control_q = cam.inputControl.createInputQueue()
2
3ctrl = dai.CameraControl()
4ctrl.setAutoExposureMaxISO(800)
5control_q.send(ctrl)平台特定限制
RVC2
ISP 持续约 600 MP/s(≈ 4 K @ 30 fps)→ 在运行重型神经网络和视频编码器时相应地进行预算。 3A 在嵌入式微型 DSP 上运行,所有相机流的总和最高可达约 250 fps。
更多示例
API 参考
class
dai::node::Camera
variable
CameraControl initialControl
Initial control options to apply to sensor
variable
Input inputControl
variable
Input mockIsp
Input for mocking 'isp' functionality on RVC2. Default queue is blocking with size 8
variable
Output raw
Outputs ImgFrame message that carries RAW10-packed (MIPI CSI-2 format) frame data.Captured directly from the camera sensor, and the source for the 'isp' output.
variable
OutputMap dynamicOutputs
function
Node::Output * requestOutput(const std::pair< uint32_t, uint32_t > & size, std::optional< ImgFrame::Type > type, ImgResizeMode resizeMode, std::optional< float > fps, std::optional< bool > enableUndistortion, std::optional< float > alphaScaling)Get video output with specified size.
function
Node::Output * requestOutput(const Capability & capability, bool onHost)Request output with advanced controls. Mainly to be used by custom node writers.
function
Node::Output * requestFullResolutionOutput(std::optional< ImgFrame::Type > type, std::optional< float > fps, bool useHighestResolution)Get a high resolution output with full FOV on the sensor. By default the function will not use the resolutions higher than 5000x4000, as those often need a lot of resources, making them hard to use in combination with other nodes.
Parameters
- type: Type of the output (NV12, BGR, ...) - by default it's auto-selected for best performance
- fps: FPS of the output - by default it's auto-selected to highest possible that a sensor config support or 30, whichever is lower
- useHighestResolution: If true, the function will use the highest resolution available on the sensor, even if it's higher than 5000x4000
function
Node::Output * requestIspOutput(std::optional< float > fps)Request output with isp resolution. The fps does not vote.
function
std::shared_ptr< Camera > build(dai::CameraBoardSocket boardSocket, const std::optional< std::pair< uint32_t, uint32_t >> & sensorResolution, std::optional< float > sensorFps)Build with a specific board socket
Parameters
- boardSocket: Board socket to use
- sensorResolution: Sensor resolution to use - by default it's auto-detected from the requested outputs
- sensorFps: Sensor FPS to use - by default it's auto-detected from the requested outputs (maximum is used)
inline function
std::shared_ptr< Camera > setSensorType(CameraSensorType sensorType)Set the sensor type to use
Parameters
- sensorType: Sensor type to use
inline function
CameraSensorType getSensorType()Get the sensor type
Returns
Sensor type
function
std::shared_ptr< Camera > setImageOrientation(CameraImageOrientation imageOrientation)Set camera image orientation
Parameters
- imageOrientation: Image orientation to set
Returns
Shared pointer to the camera node
function
CameraImageOrientation getImageOrientation()Get camera image orientation
Returns
Image orientation
function
std::shared_ptr< Camera > build(dai::CameraBoardSocket boardSocket, ReplayVideo & replay)Build with a specific board socket and mock input
function
std::shared_ptr< Camera > build(ReplayVideo & replay)Build with mock input
function
uint32_t getMaxWidth()Get max width of the camera (can only be called after build)
function
uint32_t getMaxHeight()Get max height of the camera (can only be called after build)
function
CameraBoardSocket getBoardSocket()Retrieves which board socket to use
Returns
Board socket to use
function
std::shared_ptr< Camera > setRawNumFramesPool(int num)Set number of frames in raw pool (will be automatically reduced if the maximum pool memory size is exceeded)
Parameters
- num: Number of frames
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setMaxSizePoolRaw(int size)Set maximum size of raw pool
Parameters
- size: Maximum size in bytes of raw pool
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setIspNumFramesPool(int num)Set number of frames in isp pool (will be automatically reduced if the maximum pool memory size is exceeded)
Parameters
- num: Number of frames
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setMaxSizePoolIsp(int size)Set maximum size of isp pool
Parameters
- size: Maximum size in bytes of isp pool
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setNumFramesPools(int raw, int isp, int outputs)Set number of frames in all pools (will be automatically reduced if the maximum pool memory size is exceeded)
Parameters
- raw: Number of frames in raw pool
- isp: Number of frames in isp pool
- outputs: Number of frames in outputs pools
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setMaxSizePools(int raw, int isp, int outputs)Set maximum memory size of all pools
Parameters
- raw: Maximum size in bytes of raw pool
- isp: Maximum size in bytes of isp pool
- outputs: Maximum size in bytes of outputs pools
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setOutputsNumFramesPool(int num)Set number of frames in pools for all outputs
Parameters
- num: Number of frames in pools for all outputs
Returns
Shared pointer to the camera node
function
std::shared_ptr< Camera > setOutputsMaxSizePool(int size)Set maximum size of pools for all outputs
Parameters
- size: Maximum size in bytes of pools for all outputs
Returns
Shared pointer to the camera node
function
int getRawNumFramesPool()Get number of frames in raw pool
Returns
Number of frames
function
int getMaxSizePoolRaw()Get maximum size of raw pool
Returns
Maximum size in bytes of raw pool
function
int getIspNumFramesPool()Get number of frames in isp pool
Returns
Number of frames
function
int getMaxSizePoolIsp()Get maximum size of isp pool
Returns
Maximum size in bytes of isp pool
function
std::optional< int > getOutputsNumFramesPool()Get number of frames in outputs pool for all outputs
Returns
Number of frames
function
std::optional< size_t > getOutputsMaxSizePool()Get maximum size of outputs pool for all outputs
Returns
Maximum size in bytes of image manip pool
function
Camera & setMockIsp(ReplayVideo & replay)Set mock ISP for Camera node. Automatically sets mockIsp size.
Parameters
- replay: ReplayVideo node to use as mock ISP
function
Camera()explicit function
Camera(std::shared_ptr< Device > & defaultDevice)explicit function
Camera(std::unique_ptr< Properties > props)function
void buildStage1()Build stages;.
function
float getMaxRequestedFps()function
uint32_t getMaxRequestedWidth()function
uint32_t getMaxRequestedHeight()inline function
DeviceNodeCRTP()inline function
DeviceNodeCRTP(const std::shared_ptr< Device > & device)inline function
DeviceNodeCRTP(std::unique_ptr< Properties > props)inline function
DeviceNodeCRTP(std::unique_ptr< Properties > props, bool confMode)inline function
DeviceNodeCRTP(const std::shared_ptr< Device > & device, std::unique_ptr< Properties > props, bool confMode)需要帮助?
请访问讨论论坛以获取技术支持或您可能有的任何其他问题。