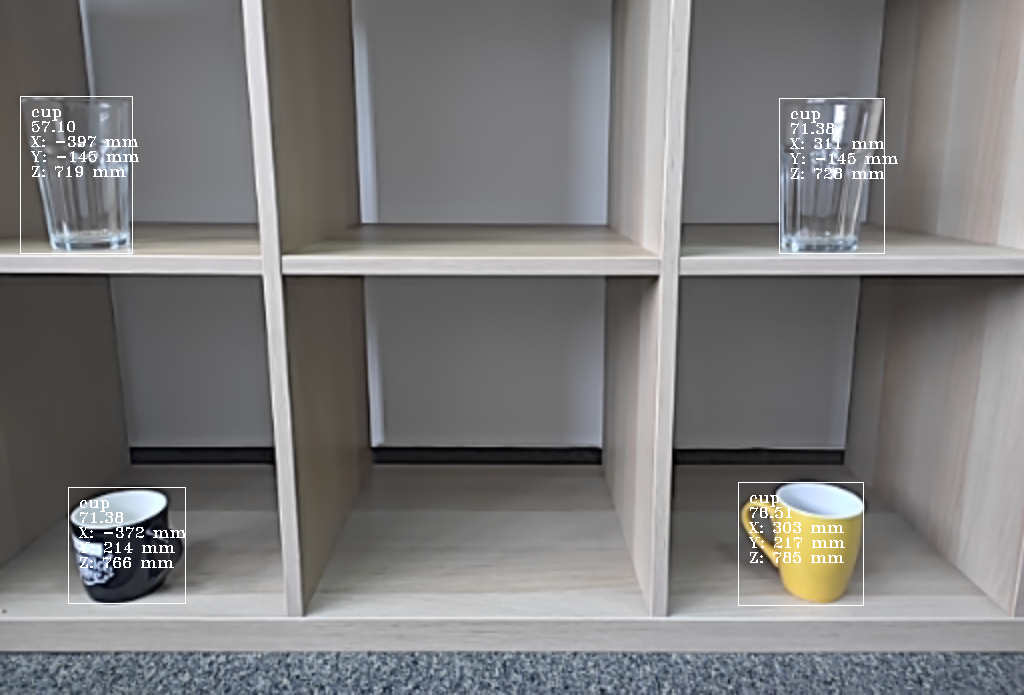
inputDepth 中的 depth 图计算 ROI(感兴趣区域)的空间坐标。它将平均 ROI 中的深度值并移除超出范围的值。您也可以在主机端计算空间坐标,此处有演示。该演示还包含在设备上执行的相同逻辑(calc.py 文件)。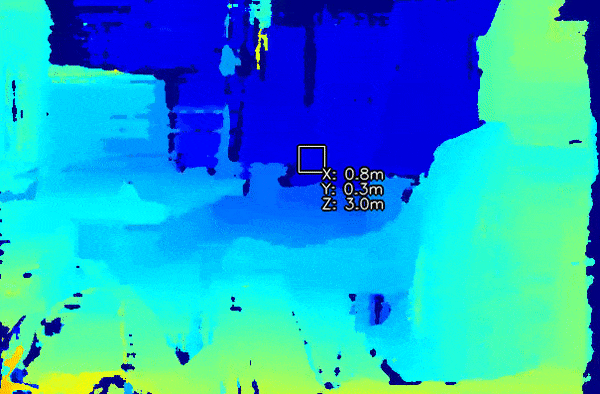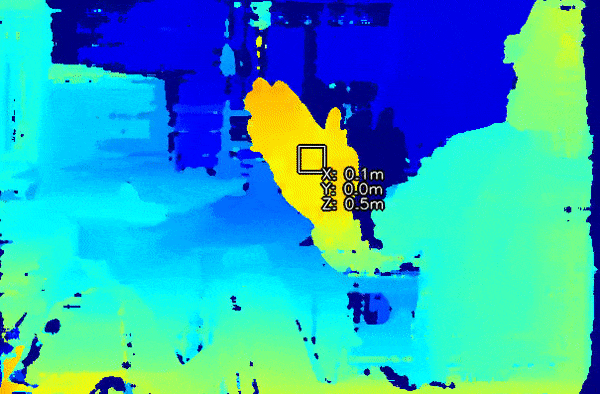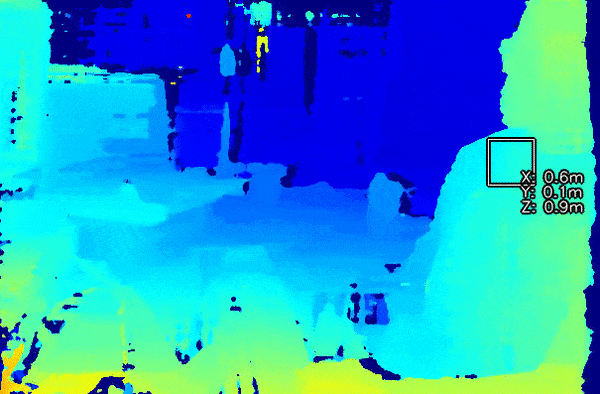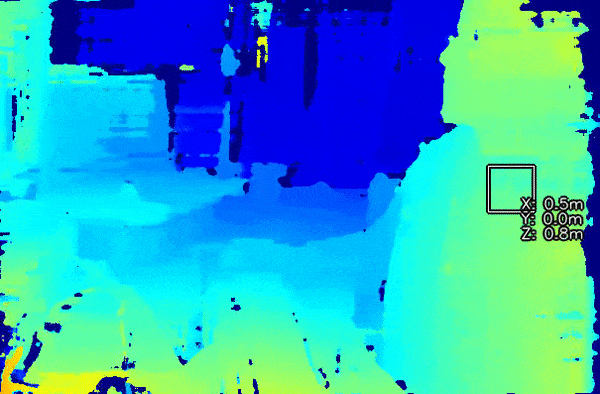
如何放置
Python
Python
1pipeline = dai.Pipeline()
2spatialCalc = pipeline.create(dai.node.SpatialLocationCalculator)输入和输出
用法
Python
Python
1pipeline = dai.Pipeline()
2spatialCalc = pipeline.create(dai.node.SpatialLocationCalculator)
3spatialCalc.setWaitForConfigInput(False)
4
5# 设置初始配置
6config = dai.SpatialLocationCalculatorConfigData()
7config.depthThresholds.lowerThreshold = 100
8config.depthThresholds.upperThreshold = 10000
9
10topLeft = dai.Point2f(0.4, 0.4)
11bottomRight = dai.Point2f(0.6, 0.6)
12config.roi = dai.Rect(topLeft, bottomRight)
13
14spatial_calc.initialConfig.addROI(config)
15
16# 您可以稍后从主机 (XLinkIn) / Script 节点向 InputConfig 发送配置功能示例
空间坐标系
参考
class
dai::node::SpatialLocationCalculator
variable
std::shared_ptr< SpatialLocationCalculatorConfig > initialConfig
Initial config to use when calculating spatial location data.
variable
Input inputConfig
Input SpatialLocationCalculatorConfig message with ability to modify parameters in runtime. Default queue is non-blocking with size 4.
variable
Input inputDetections
Input messages on which spatial location will be calculated. Possible datatypes are ImgDetections or Keypoints.
variable
Input inputDepth
Input message with depth data used to retrieve spatial information about detected object. Default queue is non-blocking with size 4.
variable
Output out
Outputs SpatialLocationCalculatorData message that carries spatial locations for each additional ROI that is specified in the config.
variable
Output outputDetections
variable
Output passthroughDepth
Passthrough message on which the calculation was performed. Suitable for when input queue is set to non-blocking behavior.
function
SpatialLocationCalculator()inline function
SpatialLocationCalculator(std::unique_ptr< Properties > props)function
void setRunOnHost(bool runOnHost)Specify whether to run on host or device By default, the node will run on device.
function
bool runOnHost()Check if the node is set to run on host
function
void run()inline function
DeviceNodeCRTP()inline function
DeviceNodeCRTP(const std::shared_ptr< Device > & device)inline function
DeviceNodeCRTP(std::unique_ptr< Properties > props)inline function
DeviceNodeCRTP(std::unique_ptr< Properties > props, bool confMode)inline function
DeviceNodeCRTP(const std::shared_ptr< Device > & device, std::unique_ptr< Properties > props, bool confMode)需要帮助?
请访问讨论论坛以获取技术支持或您可能有的任何其他问题。